JaxLab GearCar: a Wooden Gear Car You Drive with One Joystick
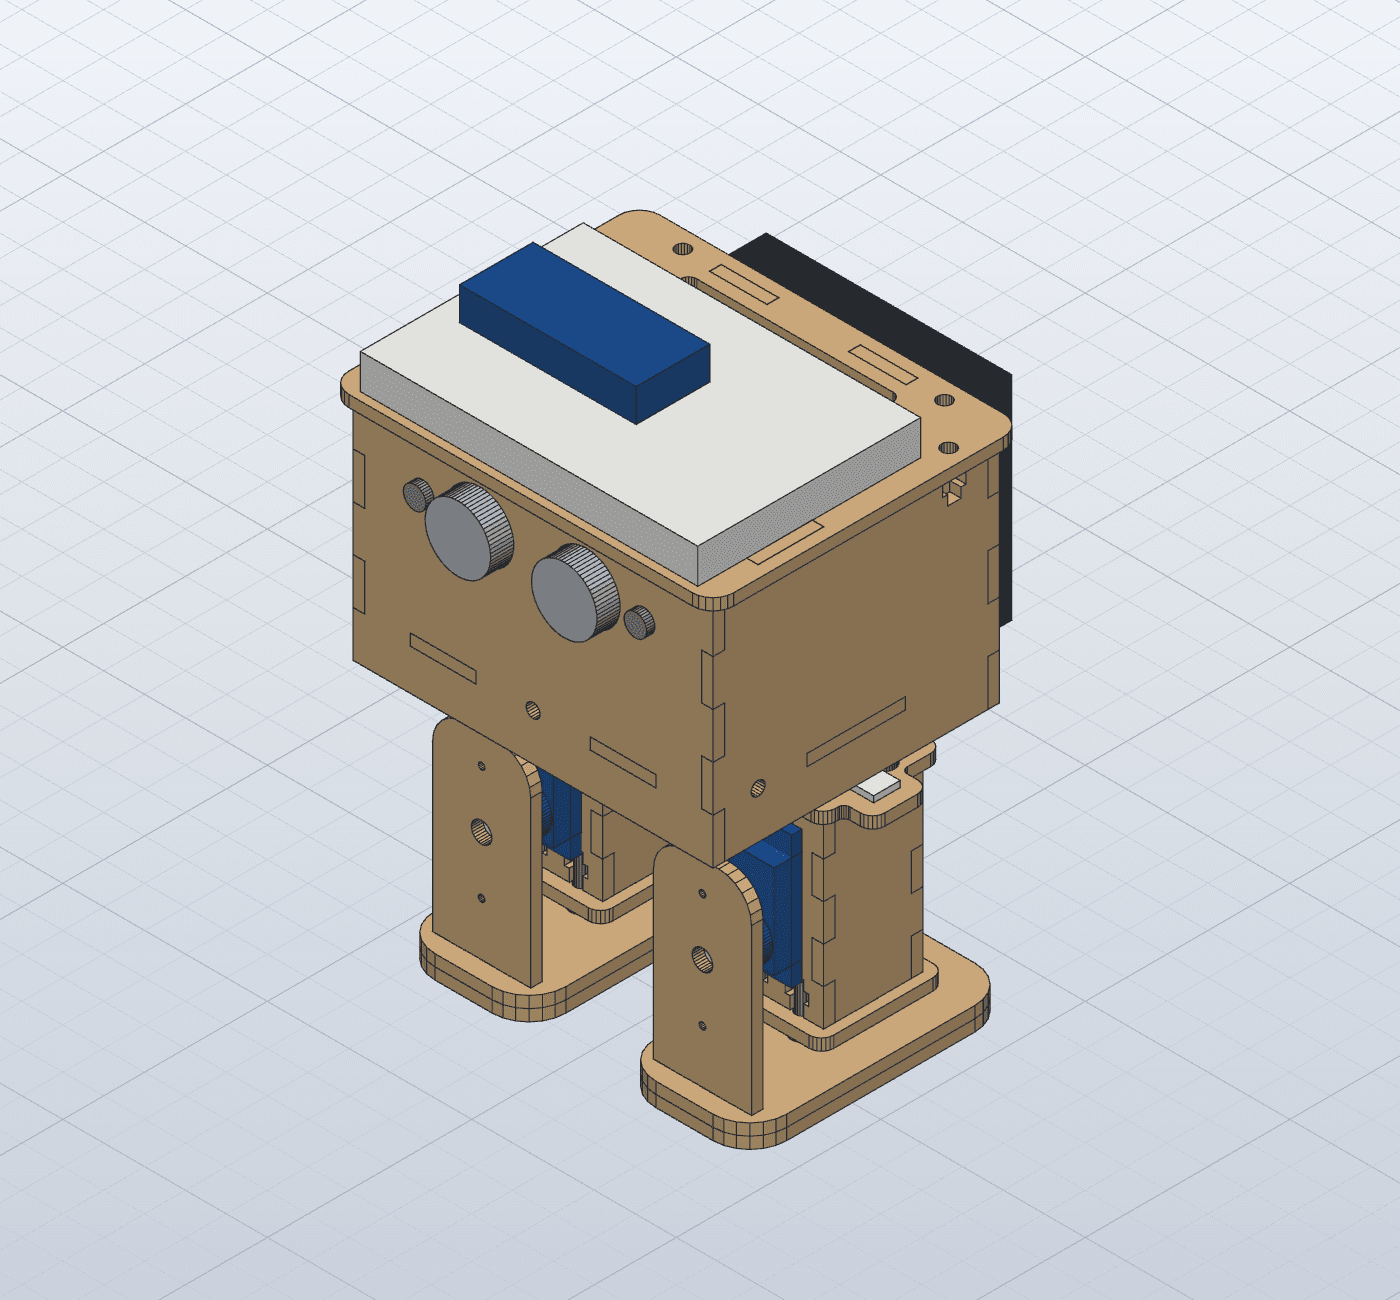
A remote-control car whose gearbox, wheels, tyres and Ackermann steering are all cut from 2.8 mm plywood. A 27:1 wooden gearbox, an ESP32-C3 and a one-stick wooden remote. For JSS1 to SS3.
Project Overview
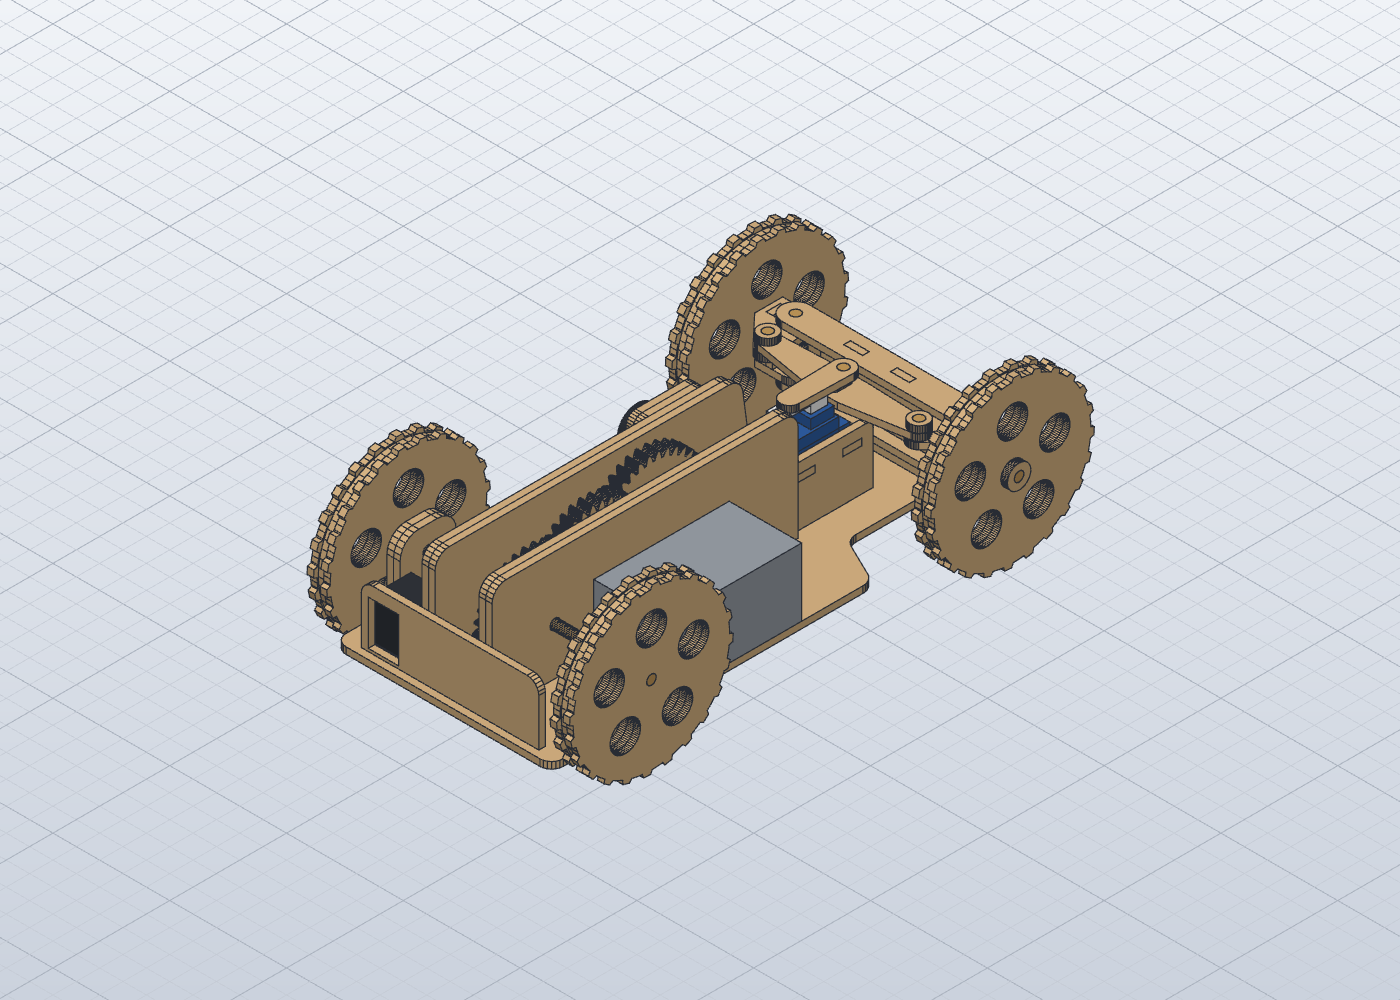
The GearCar is a toy car where you can see every part of the drive working. The motor turns a wooden gearbox with three 12T to 36T stages, which gives 27 : 1. The wheels have laminated wooden tyres, and the front wheels steer with real Ackermann steering. The only bought parts are the motor, the servo, the electronics and the dowels.
You drive it with a small wooden remote with one joystick: push forward to go, pull back to reverse, and push left or right to steer. Click the stick to switch between SLOW and FAST. The remote and the car talk directly over ESP-NOW, so no phone, Wi-Fi network or pairing is needed.
Designed and checked, not built yet
Every part, fit and motion in this kit was checked by script, but nobody has built one yet. Part sizes are typical values: measure yours and cut the fit test before the full sheets.
At a glance
| Specification | Value |
|---|---|
| Size | 119 wide x 224 long x 70 mm high, 70 mm wheels |
| Weight (calculated) | About 290 g with 4 AA cells |
| Drive | "130" DC motor, wooden gearbox 27 : 1, about 0.9 m/s |
| Steering | SG90 servo, Ackermann knuckles, inner wheel 25 degrees |
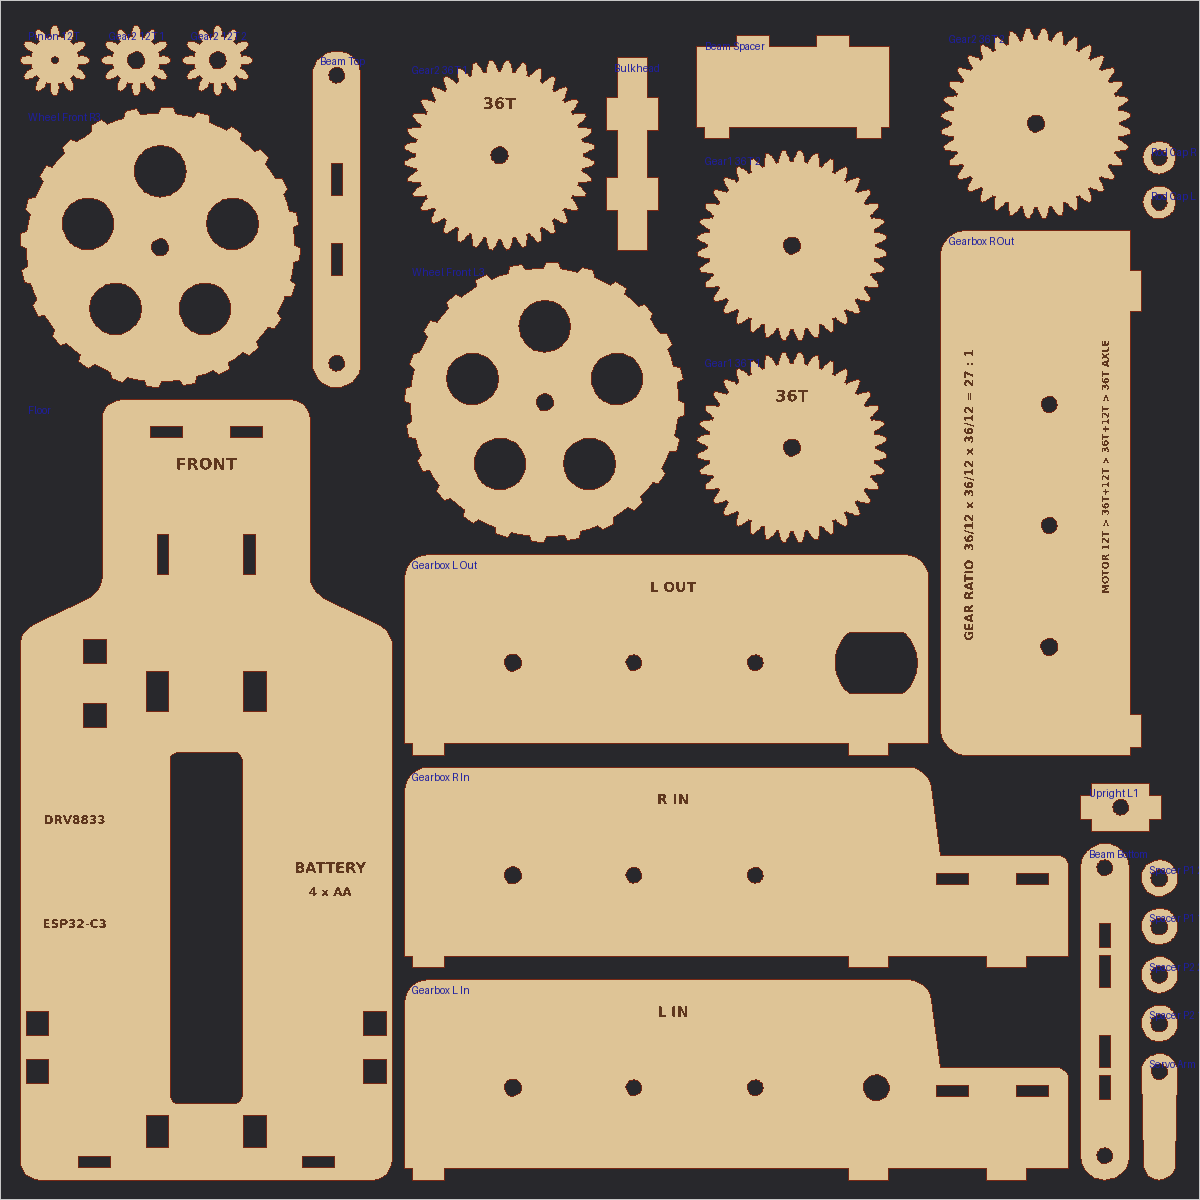
| Wood | 62 car parts on two 300 x 300 mm sheets, plus 29 remote parts |
| Remote | 64 x 132 x 25 mm, one thumbstick, ESP32-C3, 3 AA |
| Price | ₦45,000 per box (Hack Pack, see Subscribe) |
| Class | JSS1 to SS3 |
What it teaches
- Gear ratio: 36 / 12 = 3 per stage, and 3 x 3 x 3 = 27. The tooth counts are engraved on the gears so students can check the sum, and count turns by hand.
- Speed against torque: the motor is fast and weak, and the gears trade speed for turning force.
- Ackermann steering: the inside wheel turns more than the outside one (25 and 22 degrees).
- Circuits and radio: battery, switch, motor driver, servo, two microcontrollers talking by radio.
Downloads
| File | Use |
|---|---|
| Fit test G-code | Cut this first |
| Car sheet 1 G-code | Floor, gearbox sides, gears, steering (engrave, then cut) |
| Car sheet 2 G-code | Wheels, bearings, motor clamp, knuckles |
| Firmware (car + remote) | Two Arduino sketches for ESP32-C3 SuperMini boards |
| CAD files | STEP models, SVG sheets, and the remote case G-code |
🛒 Materials Needed
- 2 sheets of 2.8 mm plywood, 300 x 300 mm (car) + 1 sheet and an offcut (remote)
- 3 V "130" DC motor
- SG90 servo
- 2 ESP32-C3 SuperMini boards (car and remote)
- DRV8833 motor driver module
- 4 x AA holder (2 x 2) and 4 AA cells (NiMH rechargeable is best)
- Mini rocker switch
- 1N4007 diode
- 4 mm wooden dowel or bamboo skewers, about 40 cm
- Thumbstick module (KY-023) for the remote
- 3 x AA box with switch and 3 AA cells for the remote
- 6 M2 x 8 and 4 M2 x 12 self-tapping screws (remote)
- Wood glue, CA glue, candle wax
📋 Step-by-Step Instructions
Cut Fit test G-code first. It checks the parts most likely to differ from the design:
- The motor can fits its shaped hole.
- Your dowel turns freely in one hole and grips in the other.
- A 12T and a 36T gear on two dowels turn smoothly, without binding or skipping.
- The small ring presses onto the motor shaft.
If the gears bind, raise CD in the design script by 0.1 to 0.2 mm; if they skip, lower it. Bamboo skewers vary a lot, so measure yours.
Step Images
All 6 steps completed — great work!